When companies begin looking for a tote ASRS supplier, the first comparison sheet usually fills up quickly.
Robot speed. Payload. Storage height. Positioning accuracy. Price per unit.
These figures are easy to collect, but they rarely explain whether the proposed warehouse will work.
In project planning, we are usually more concerned about the interfaces between the figures. A shuttle may travel quickly, but can the lifter receive its totes at the same rate? A warehouse may contain 20,000 locations, but does it have enough empty positions for returns and replenishment? If one transfer point stops, how much inventory becomes inaccessible?
Those questions reveal more about a supplier than the robot specification alone.
Start with the Material Flow, Not the Supplier List
A tote ASRS is generally used for small parts, components, cartons or individual products stored in standardized containers. The equipment may include four-way shuttles, two-way shuttles, Miniload Cranes or autonomous case-handling robots.
These technologies are not interchangeable.
A four-way shuttle can change aisles within the racking and share work across a larger storage area. This is useful when a project needs high density, multiple robots and flexible task allocation.
A two-way shuttle follows a more fixed route. It may be sufficient when the flow is predictable and the project does not need frequent cross-aisle movement.
A Miniload Crane serves a dedicated aisle. It remains a practical choice when loads are heavier, routes are stable or the customer wants clearly defined aisle performance.
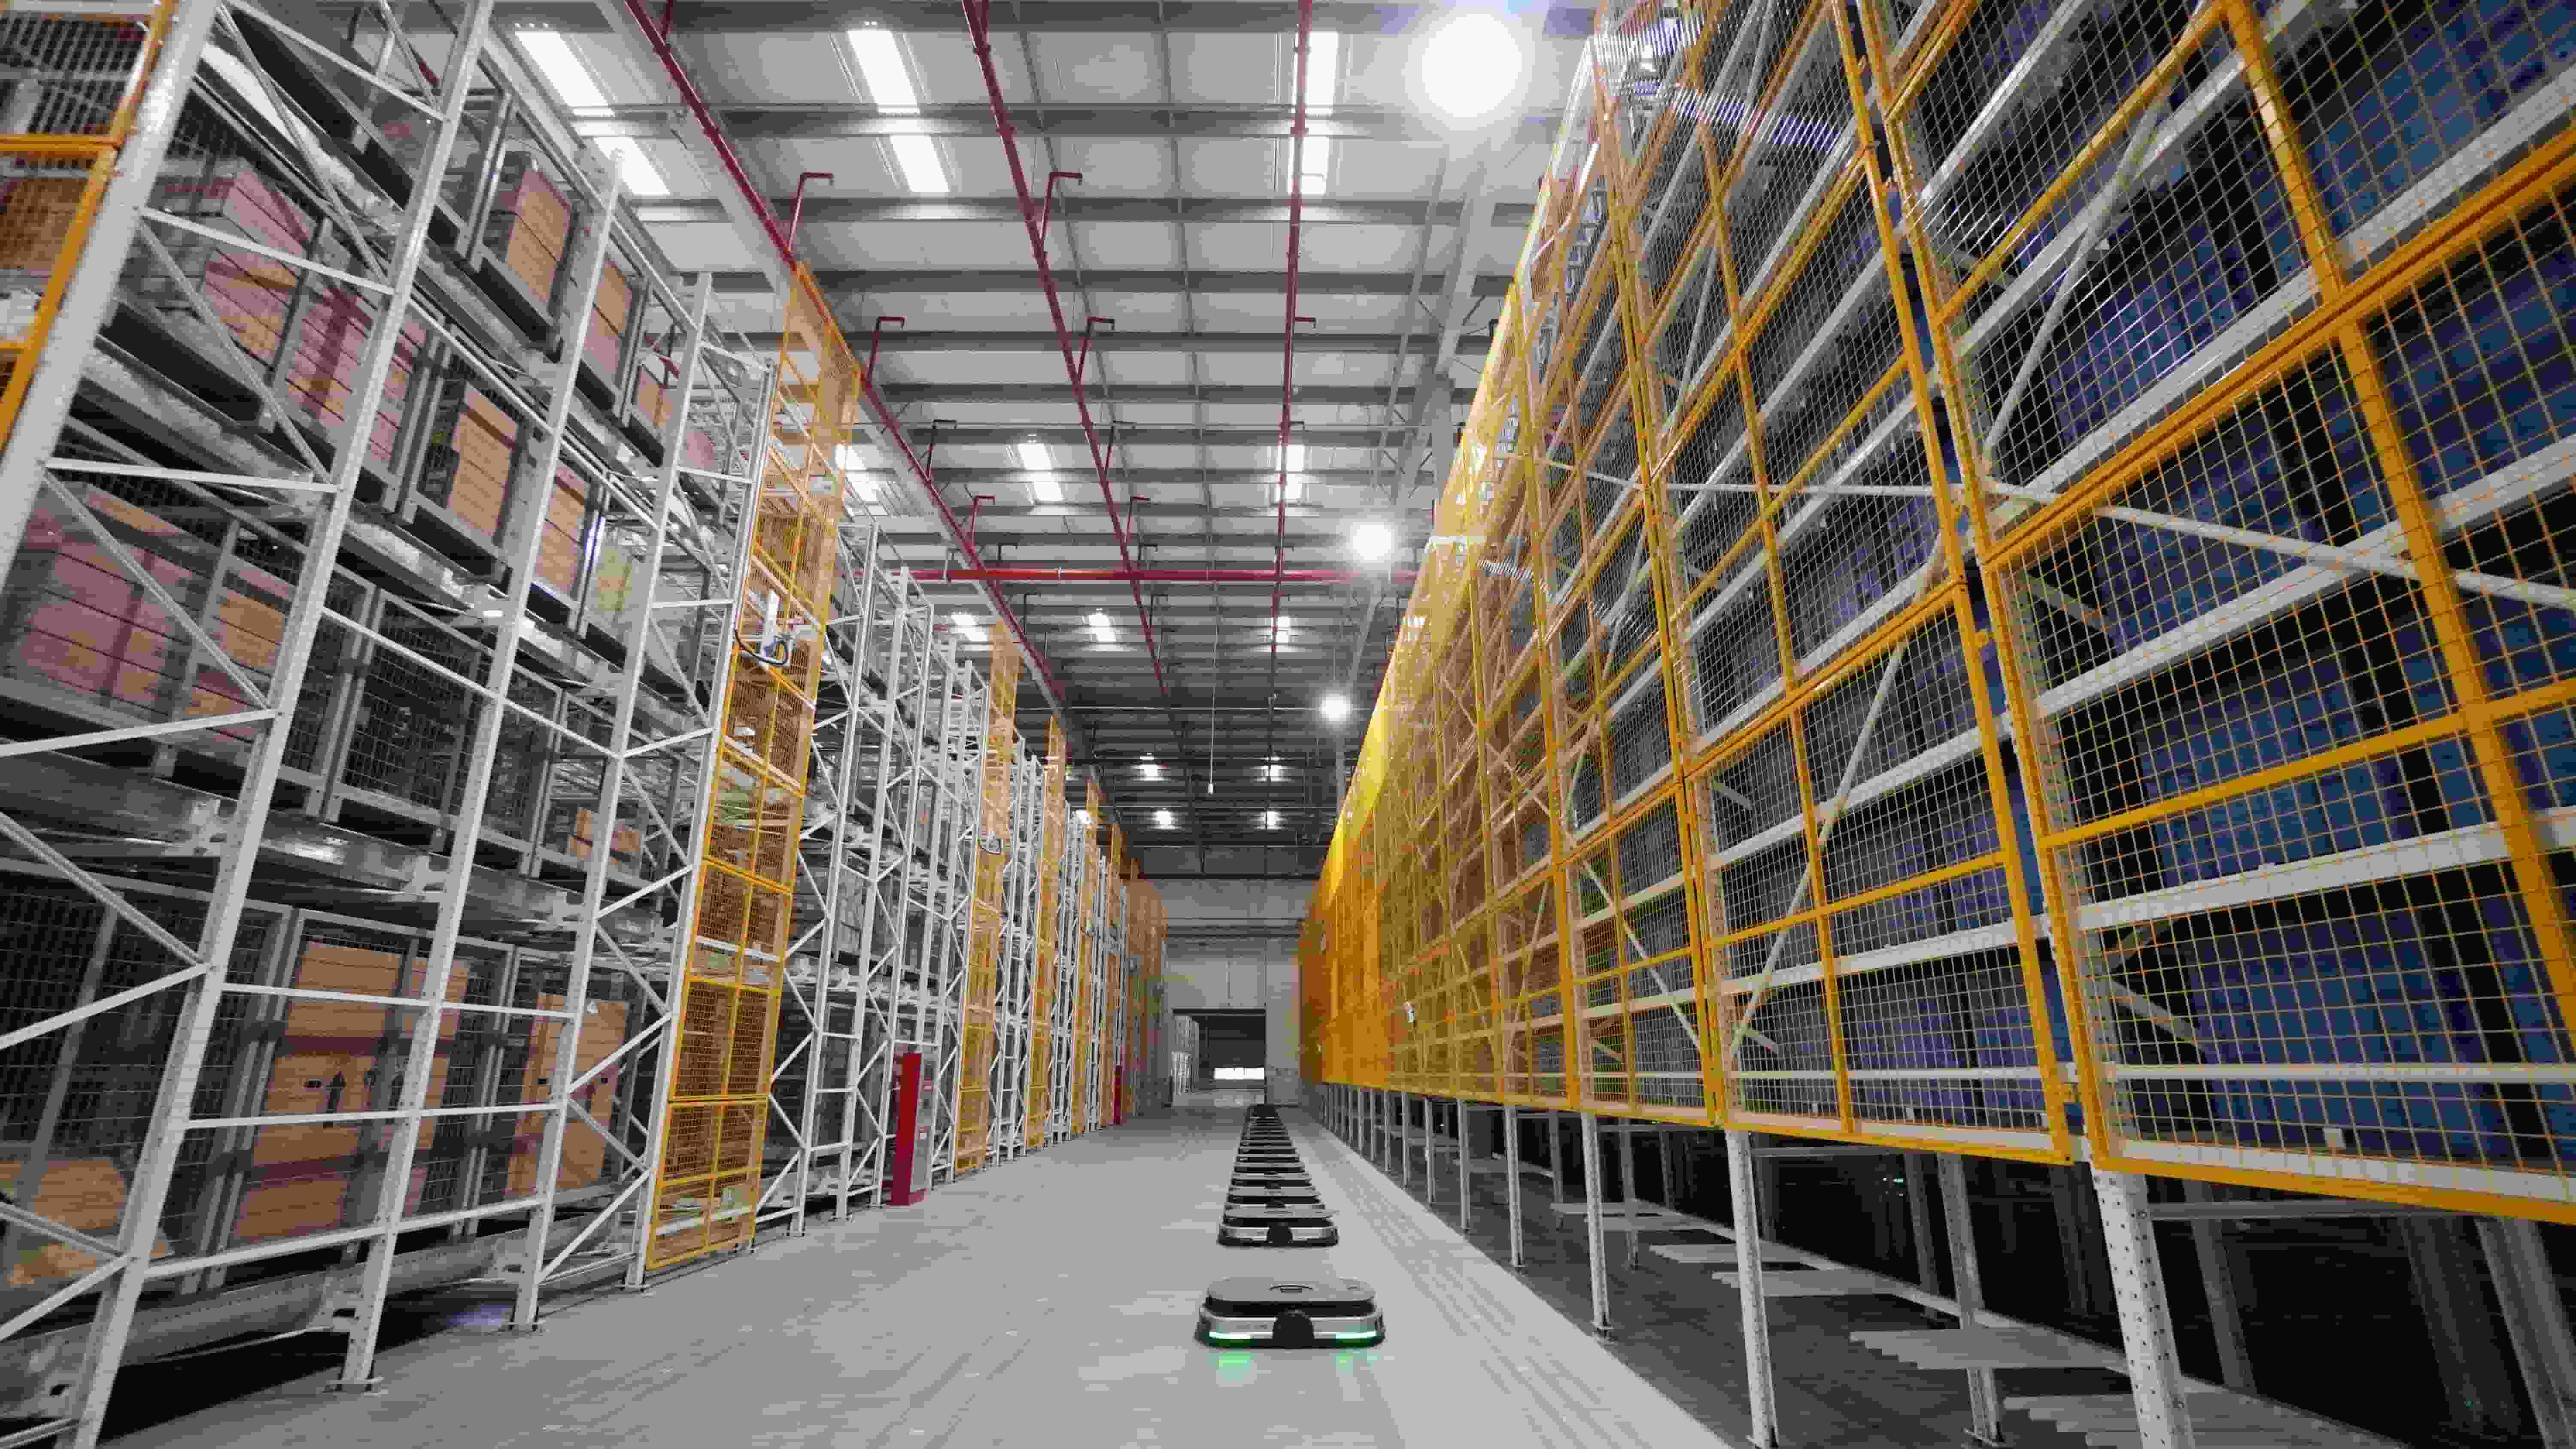
Autonomous case-handling robots approach the problem differently. They retrieve totes or cartons directly from shelving and carry them toward workstations. This can be attractive in lower buildings or retrofit projects where installing a high-bay rail system would be difficult.
The first selection should therefore be between operating concepts, not company names.
A Real Project Shows Why SKU Count Is Not Enough
In one precision manufacturing project, the customer needed to manage more than 9,700 component specifications.
The obvious response was to create more storage locations. The less obvious issue was how much working space the system needed after those locations were built.
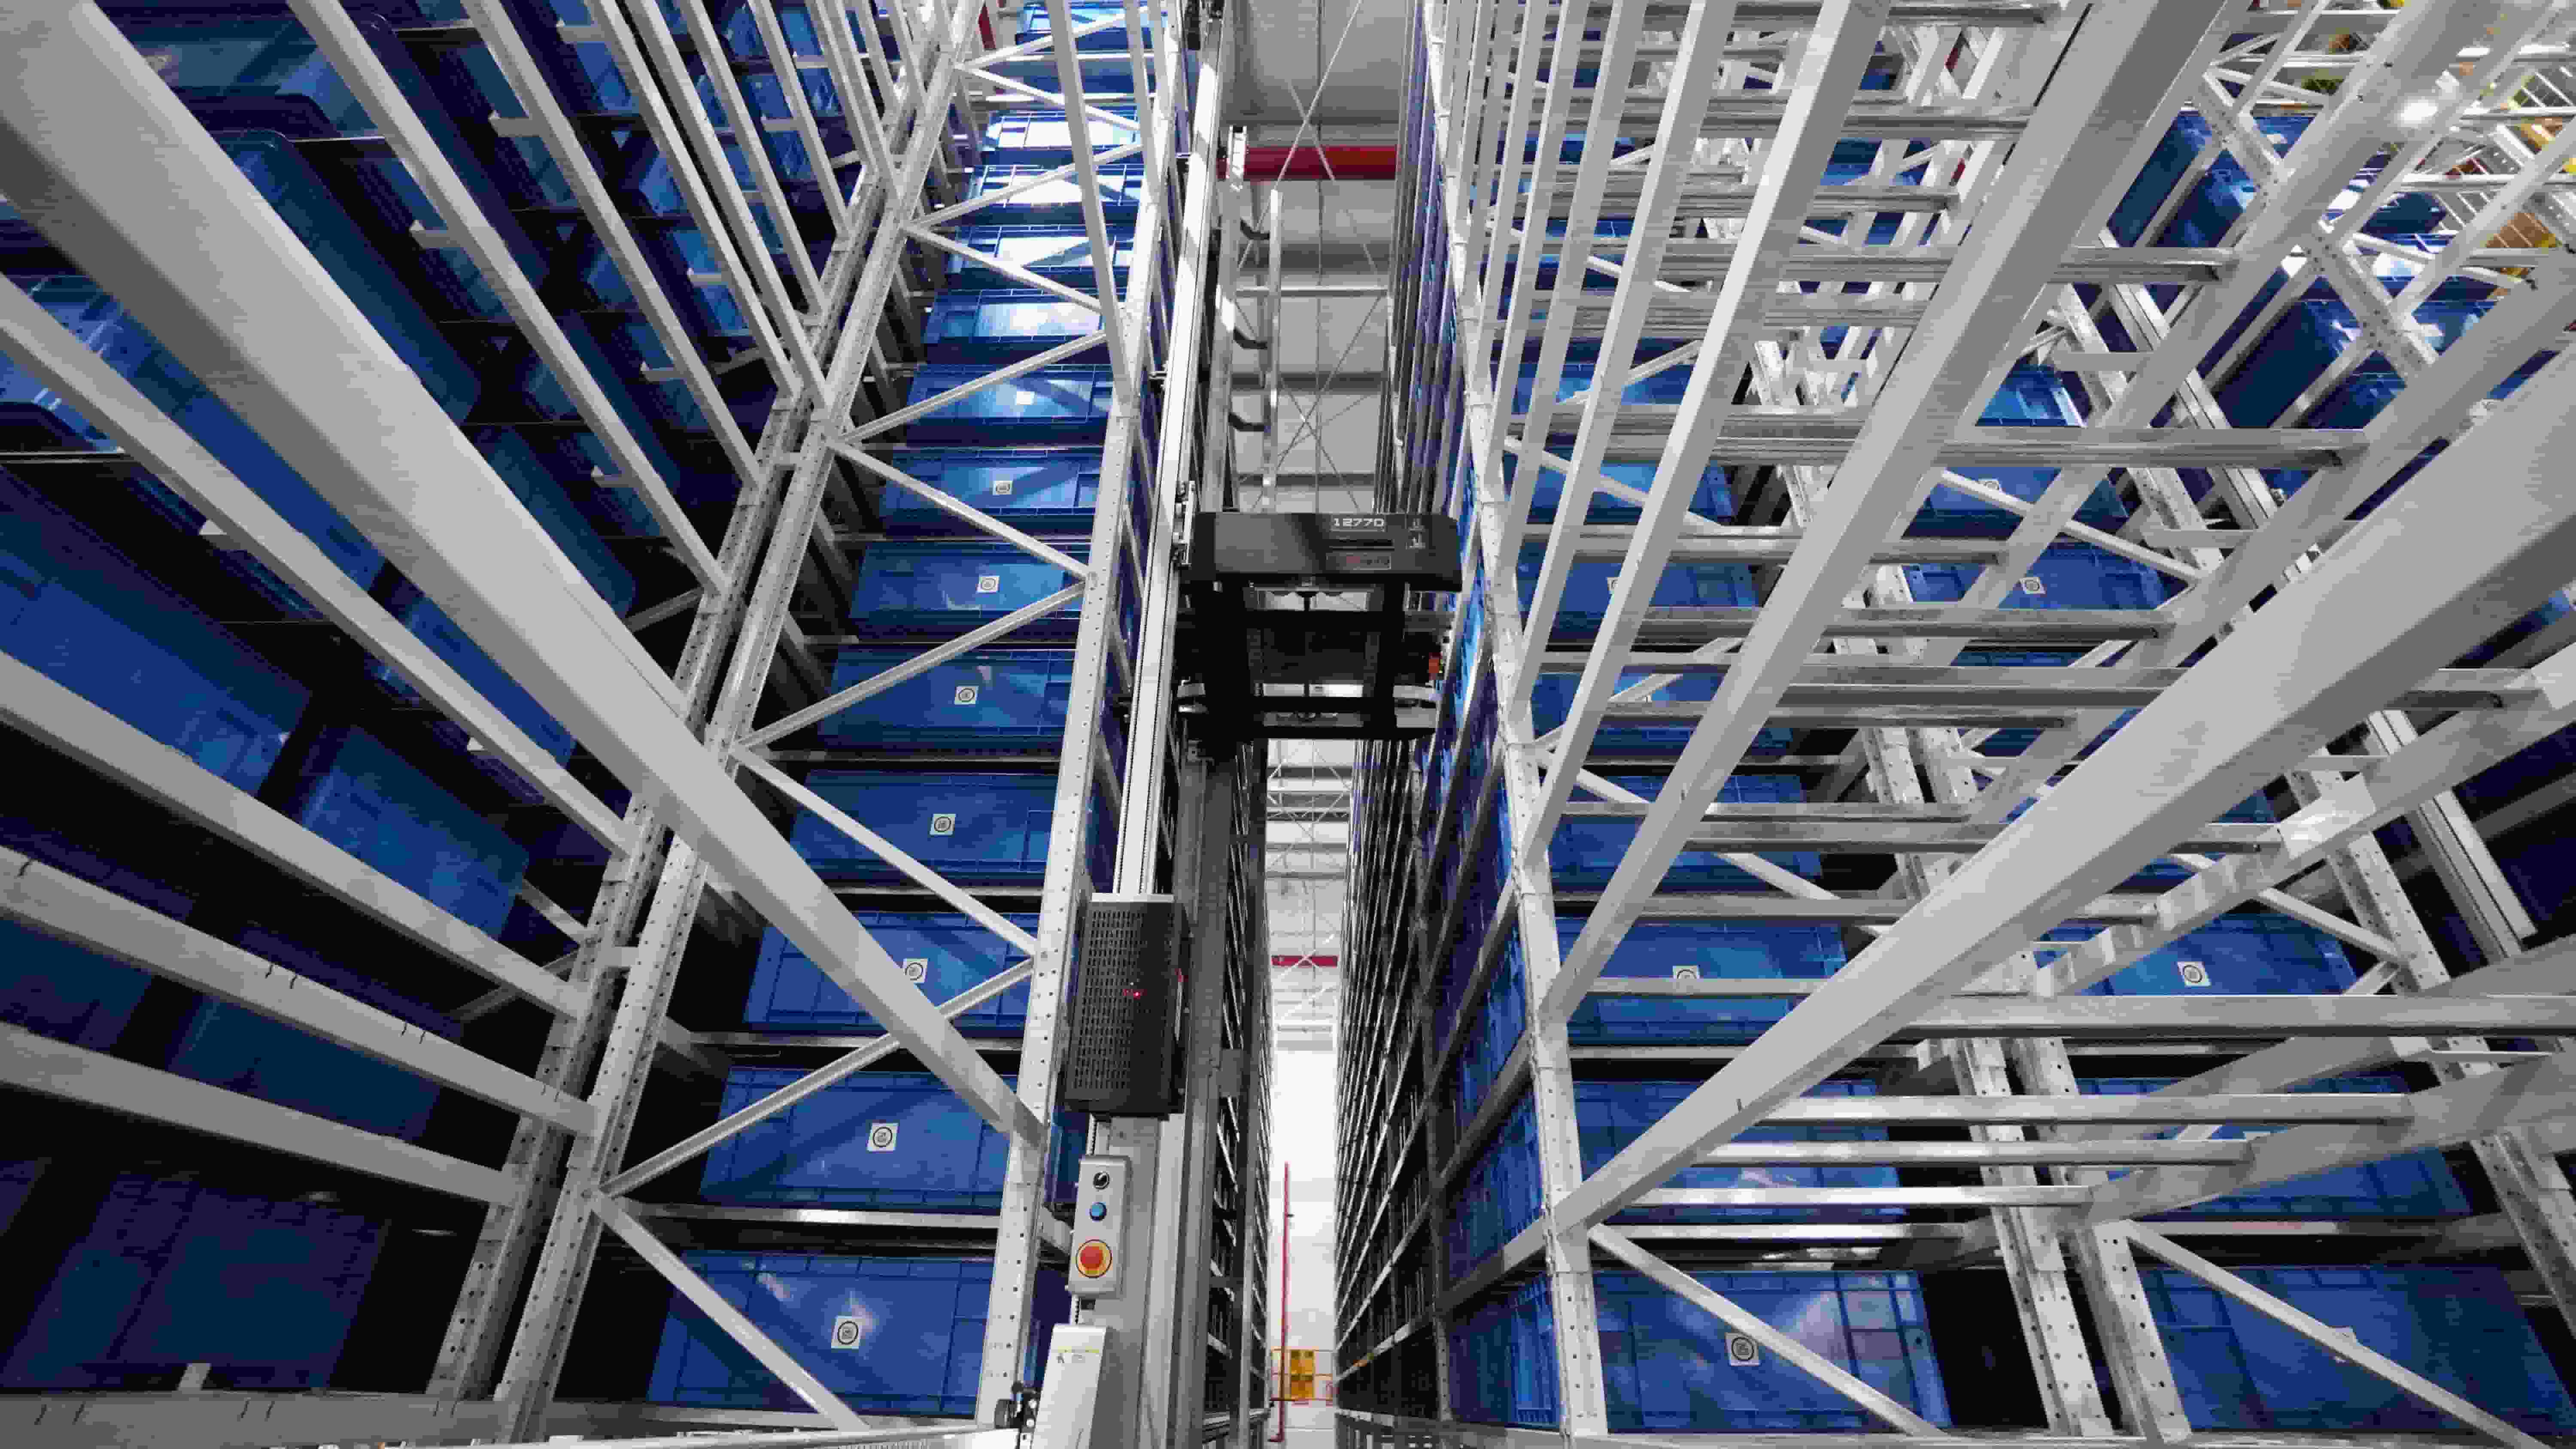
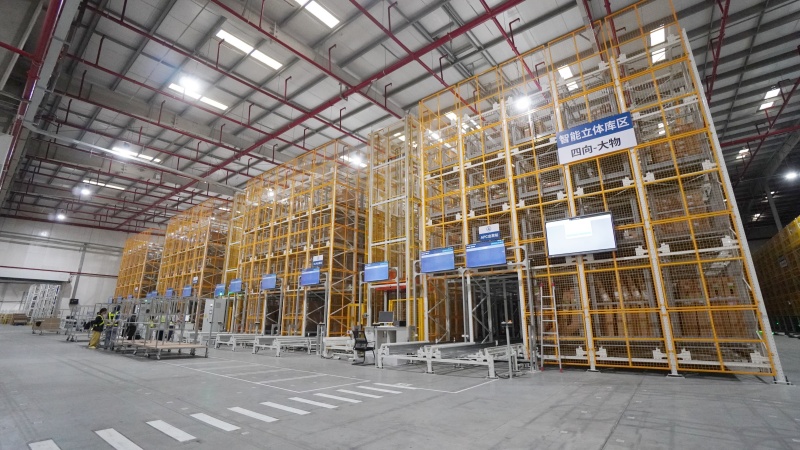
The final tote four-way shuttle ASRS reached 22.3 meters and provided more than 18,700 tote positions. It was designed to support 323 totes per hour.
The difference between 9,700 SKUs and 18,700 locations was not excess capacity.
Frequently used components required stock in several totes. Materials returning from production needed somewhere to go. Newly received goods could not enter if every position was already occupied. The system also required enough open locations to avoid constant internal rearrangement.
This is why we do not judge a proposal by dividing location count by SKU count. Inventory depth, replenishment frequency, return flow and the required operating vacancy all affect the real capacity.
The same applies to throughput.
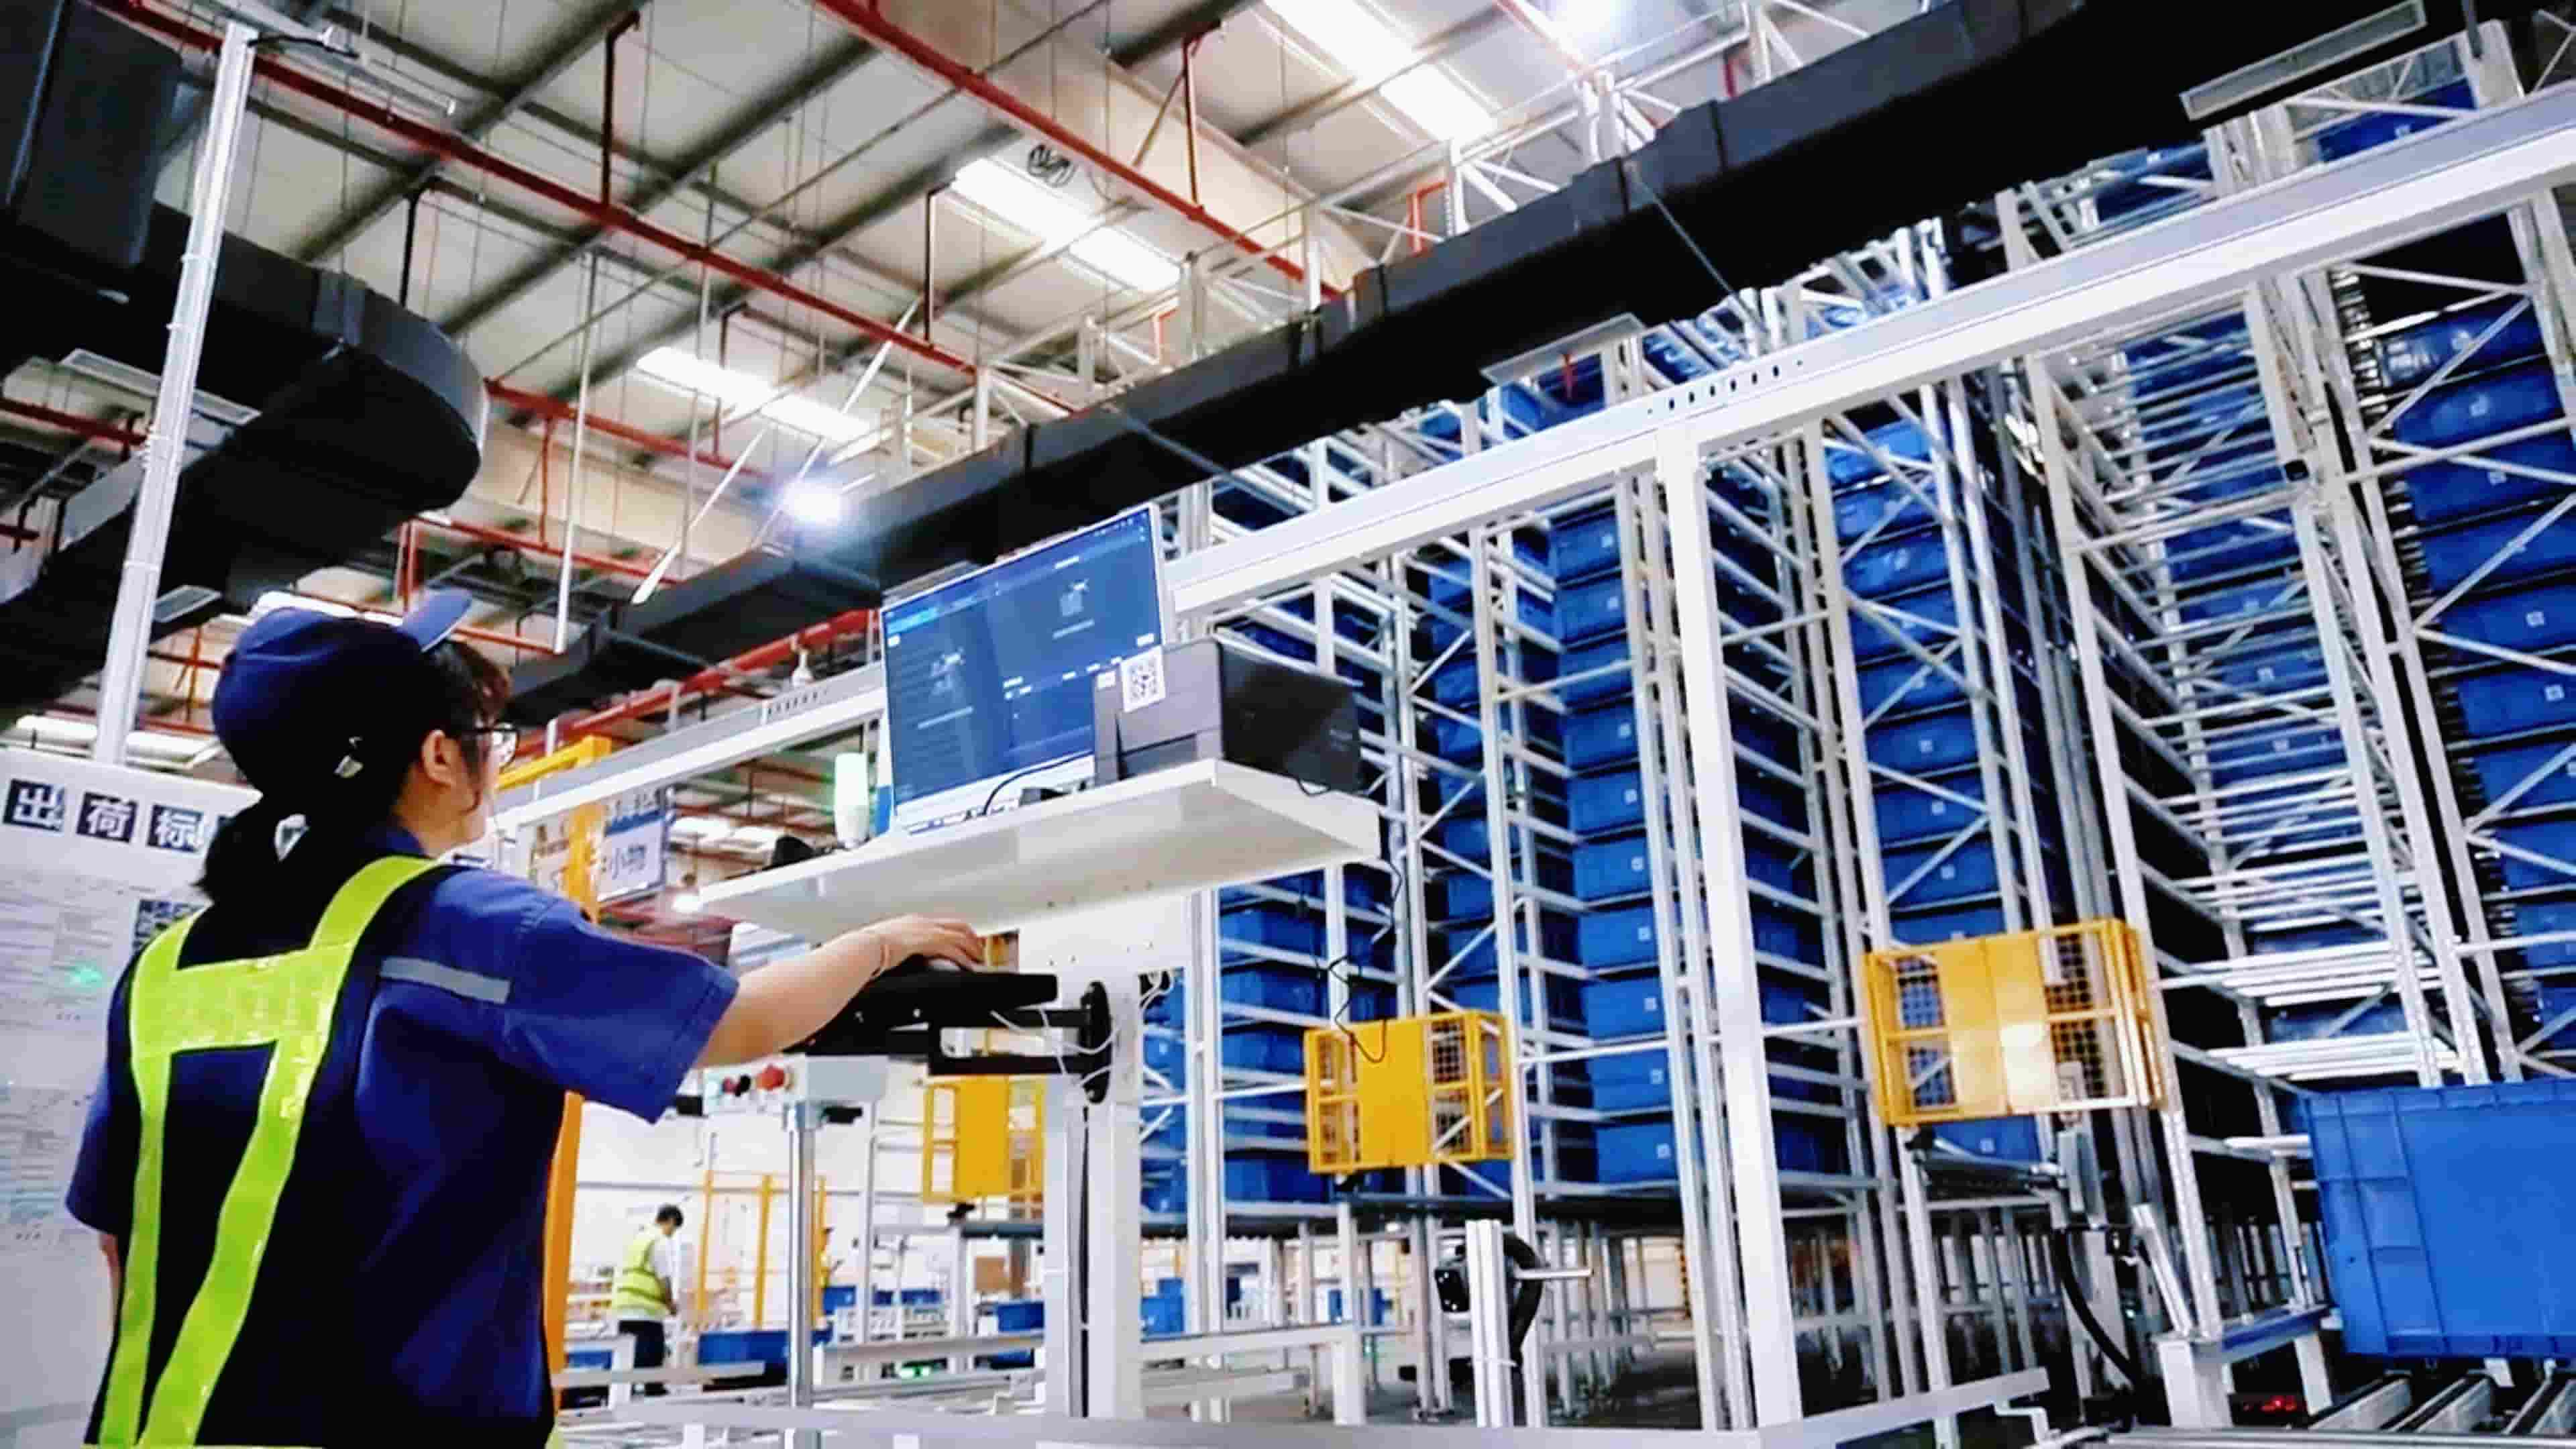
The project’s 323-tote-per-hour target did not come from shuttle speed alone. Totes had to move through shuttles, lifters, RGVs, conveyors and operating points. Increasing robot quantity would have achieved little if the vertical transfer or workstation interfaces remained unchanged.
A credible supplier should be able to show how the complete route reaches the target—not merely multiply a robot’s theoretical cycle rate by the number of vehicles.
Different Suppliers Solve the Tote Problem Differently
The current market includes suppliers with quite different technical backgrounds.
DELIECNfocuses on rail-based Tote Shuttle Systems, including four-way, two-way, dual-station and cold-storage configurations. Its projects can combine shuttles with tote lifters, conveyors, workstations and WMS/WCS. This route is most relevant when the customer wants a high-density ASRS and needs the supplier to coordinate both core equipment and software.
Geek+ approaches tote handling through mobile robotics. Its RoboShuttle concept uses high-reaching robots to retrieve totes and smaller robots to deliver them to workstations. The company positions it for high-SKU and high-throughput tote-to-person operations, with storage reaching approximately 11 meters.
HAI Robotics is known for autonomous case-handling robots. Its HaiPick systems can work with totes and cartons in different sizes, which may reduce decanting when the original packaging is suitable for automated handling. This can be useful in retail, apparel, 3PL and retrofit environments where container variety matters.
BlueSword offers a wider mix of case-handling concepts, including Shuttle Storage and rack-free tote stacking. Its portfolio is worth examining when a project is still comparing fixed-rack density with a more flexible deployment model.
None of these profiles makes one company the automatic winner.
A mobile case-handling system may suit a warehouse that values rapid deployment and carton compatibility. A rail-based four-way shuttle may fit a taller facility where density and high-volume tote retrieval matter more. A Miniload System may be preferable when dedicated aisles and heavier loads are required.
The correct shortlist depends on the warehouse before it depends on the brand.
Questions That Expose Weak Proposals
When reviewing a tote ASRS proposal, we usually look beyond the headline performance.
What happens at peak demand?
Average hourly volume is rarely enough. The supplier should model simultaneous inbound, replenishment, picking and return tasks during the busiest operating window.
Where will totes wait?
Buffers are necessary between storage, level changing and workstations. Too little buffer creates equipment waiting; too much consumes space and complicates sequencing.
What becomes unavailable during a fault?
If one shuttle stops, other robots may take over its tasks. If the only lifter stops, however, an entire storage zone may be isolated. Recovery routes and reduced-capacity operation should be discussed before installation.
Do all materials belong in totes?
Large components, handling frames and heavier items may be better stored on pallets. A mixed tote-and-pallet design is often more practical than repacking every material into one standard container.
Who owns the interfaces?
The proposal should identify who supplies the racking, robots, lifters, conveyors, software and commissioning. When several vendors are involved, responsibility for overall throughput must still be clear.
How is software responsibility divided?
ERP or MES exchanges business information with WMS. WMS manages inventory, locations and warehouse tasks. WCS schedules the equipment that executes those tasks. The shuttle robots should not receive business instructions directly from ERP or MES.
What Is Changing in Tote ASRS Design?
One visible development is the move from single-tote to multi-tote handling.
Dual-station shuttles can handle two totes within one operating cycle. This may reduce empty travel, but it does not automatically double system throughput. Lifters, handover points and workstations still need enough capacity to receive the additional tote flow.
Container compatibility is also widening. Some robotic systems now handle both totes and cartons. This can reduce decanting, although carton strength, dimensional consistency and barcode position must be tested carefully.
A third change is the growing use of hybrid warehouses. Precision manufacturing, automotive parts and pharmaceutical facilities often contain both small components and larger units. Tote storage and pallet storage are increasingly planned as connected but separate flows.
These developments make system planning more important, not less. More equipment options create more possible combinations—and more opportunities to build a technically impressive warehouse that does not match the operation.
Final Selection Should Follow the Operating Risk
A tote ASRS supplier should be evaluated on more than whether its robot can meet a specification.
The stronger proposal explains why a particular technology fits the building, how the required throughput was calculated, where buffers are needed and how the warehouse continues operating during maintenance or a fault.
It should also acknowledge where another technology would be more appropriate.
For a high-SKU project, the most useful starting information is usually straightforward: tote dimensions and weight, SKU quantity, inventory depth, building height, peak inbound and outbound demand, workstation process and future growth.
Once those conditions are clear, comparing suppliers becomes much easier.
Without them, even the most detailed robot comparison remains mostly a comparison of machines—not a comparison of workable warehouse designs.
FAQS
Provide tote dimensions and weight, SKU count, required storage locations, inbound and outbound rates, building height, order profiles, and available layout drawings. These details allow the supplier to evaluate the material flow—not merely estimate equipment quantities.
Yes. The key issue is whether the supplier can define reliable interfaces for orders, inventory, material requests, task status, and exception feedback. Interface responsibilities should be agreed upon before software development begins.
Do not rely only on average daily volume. The design should consider peak-hour demand, order structure, replenishment frequency, workstation capacity, and recovery scenarios when equipment is temporarily unavailable.
A modular tote shuttle system can usually be expanded, but storage locations and handling capacity follow different rules. Additional racking increases capacity, while more shuttles, lifters, or workstations may be required to raise throughput.
Ask for comparable operating projects, simulation results, equipment availability assumptions, software interface experience, maintenance access, spare-parts support, and clearly defined acceptance criteria. A demonstration is useful, but verified project performance is more important.
Conclusion
The right tote ASRS supplier should be able to explain why a particular layout fits the operation—not simply why its robot is faster.
A credible proposal connects SKU growth, peak demand, workstation rhythm, building constraints, software interfaces, maintenance access, and future expansion. It should also make the design limits visible, including what happens when a shuttle, lifter, or workstation becomes unavailable.
For buyers, the most useful comparison is therefore not a list of equipment specifications. It is whether each supplier has translated the same operating data into a system that can be tested, maintained, and expanded over time. That is what determines whether an automated warehouse continues supporting production after the commissioning team has left.

 Industries
 Services
 About Us
 AS/RS Handling Robot
 Vertical Storage Module
 Conveying Equipment
 Smart Warehousing System
 Warehouse Racking