In today's super competitive world, making your warehouse run smoothly and efficiently is more important than ever if you want to stay ahead. I came across a report from the Warehousing Education and Research Council that talks about how companies that jump on automated systems, like the Asrs Shuttle System, can see a productivity boost of anywhere from 30% to 50%. Crazy, right? That’s mainly because this kind of system helps optimize space and makes retrieving items way quicker and easier.
Automation in warehouses isn’t just a passing trend anymore; it’s pretty much a must-have now. In fact, 80% of Fortune 500 companies are ramping up their automation efforts. But here’s the catch—lots of companies struggle to get it right. They often miss the mark when it comes to choosing the right technology or properly training their staff. If you don’t plan carefully, you might not get the full benefits from the Asrs Shuttle System, which kind of defeats the purpose.
And even though the Asrs Shuttle System can seriously bump up efficiency, it’s not a set-it-and-forget-it kind of deal. It’s all about regular check-ins and tweaks. Keeping an eye on performance metrics and reviewing how things are going helps spot areas where things could be better. Making these small adjustments can really help businesses unlock the system’s full potential and keep growth steady over time.
Understanding ASRS Shuttle Systems and Their Components
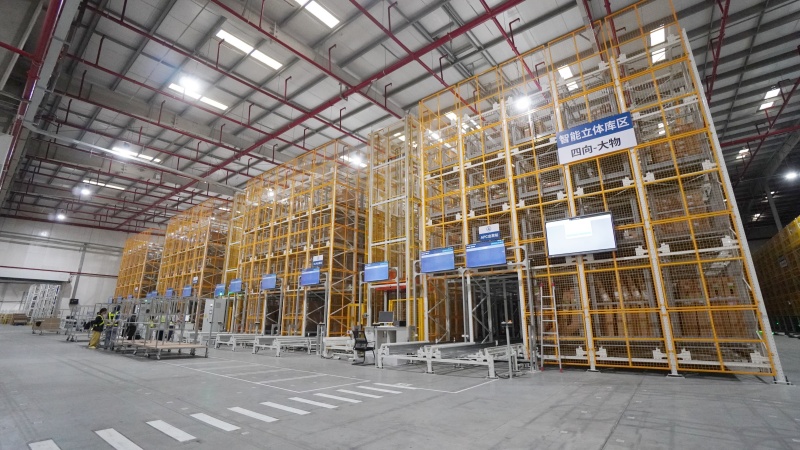
An ASRS shuttle system is an Automated Storage and retrieval solution that combines shuttle robots, high-density racking, vertical lifters, conveyors, and warehouse management software.
Within a pallet four-way shuttle system, robots move forward, backward, left, and right along a straight rail network. They can travel between main aisles and storage lanes on the same level, while lifters transfer pallets between different rack levels.
A complete system normally includes:
- Pallet four-way shuttle robots
- High-density shuttle racking
- Pallet lifters
- Conveyors
- Pallet inspection stations
- WMS and WCS software
- Safety protection and access-control devices
The system is particularly suitable for warehouses that need to store large quantities of palletized goods within limited space while maintaining flexible inbound and outbound operations.
At the FAW Toyota automotive spare-parts warehouse, DELIECN used a pallet four-way shuttle ASRS as the main storage solution for large spare parts. Other storage and handling technologies were added for small items, irregular parts, bumpers, oils, and different load formats.
This combination allowed each category of automotive spare parts to use a more suitable storage method.
Key Benefits of Implementing ASRS in Warehouses
Higher Storage Density
Traditional warehouse layouts require operating aisles between storage areas. A pallet four-way shuttle system reduces these internal aisles and uses multi-level, deep-lane storage to increase pallet capacity.
At FAW Toyota, the pallet shuttle area uses five storage levels and provides approximately 3,091 locations within a rack height of about seven metres.
The first level is designed for storage cages up to 1,675 mm high, while the upper levels accommodate cages up to 1,200 mm high. This mixed-height design improves the use of vertical space without forcing all spare parts into the same storage format.
Flexible Pallet Movement
A pallet four-way shuttle robot is not limited to one storage lane. It can serve multiple lanes on the same level and move between them according to WCS instructions.
The FAW Toyota system uses 14 DELIECN pallet four-way shuttle robots and four pallet lifters. Multiple robots can operate simultaneously, while the control system coordinates routes, transfer points, and task priorities.
This provides greater flexibility when inbound and outbound demand changes.
Reduced Manual Handling
Large automotive parts can be heavy, bulky, or stored in steel cages. Repeated manual movement increases labour intensity and creates additional safety and handling risks.
The shuttle system automates pallet movement inside the high-density racking area. Employees can remain at designated inbound, outbound, inspection, and operating stations rather than entering deep storage lanes.
Better Inventory Visibility
WMS software manages inventory data, locations, batches, task status, and movement history. WCS software converts business tasks into equipment instructions and coordinates shuttle robots, lifters, conveyors, and other handling equipment.
At FAW Toyota, the DELIECN WMS connects with the customer’s TOPSS sales system and upstream warehouse platform. Business requirements can therefore directly trigger logistics tasks.
This improves traceability and reduces dependence on manually maintained location records.
Analyzing Warehouse Processes for ASRS Integration
Before selecting an ASRS shuttle system, the warehouse process must be divided according to material characteristics and operational requirements.
The FAW Toyota project manages nearly 45,000 SKUs, including small parts, large parts, irregular components, bumpers, oils, and non-standard items. These materials differ significantly in size, weight, packaging, turnover frequency, and picking method.
DELIECN therefore did not use one storage technology for every SKU.
Large Automotive Spare Parts
Large parts stored in cages were assigned to the pallet four-way shuttle ASRS.
The system automatically completes cage receiving, location allocation, cross-level transfer, dense storage, and retrieval. Different cage heights can be managed within the same warehouse through differentiated rack levels and software-based location allocation.
Small and Medium-Sized Parts
Small and fragmented spare parts were assigned to the Mini-FlyBox ASRS.
This area provides more than 17,000 tote locations and uses 18 Mini-FlyBox robots. Required totes are automatically retrieved and delivered to fixed workstations for goods-to-person picking.
Irregular and Special Parts
Narrow-aisle racking, bumper storage areas, and two-level mezzanine racking were used for oversized, irregular, low-frequency, or manually handled materials.
Cross-Zone Transportation
The project uses 54 TOTE AMRs and 24 AGVs to connect storage areas, picking zones, workstations, and inbound and outbound areas.
By assigning different equipment to different material flows, the warehouse avoids forcing unsuitable goods into a single automated system.
Steps to Select the Right ASRS Shuttle System for Your Needs
1. Confirm the Load Unit
The first step is to confirm whether the goods use pallets, totes, cartons, or customized carriers.
The shuttle robot, racking, conveyors, and lifters must all be designed around the approved load-unit specifications.
2. Analyze SKU and Inventory Structure
The solution should consider the number of SKUs, inventory quantity per SKU, turnover frequency, batch requirements, and order characteristics.
A high-density pallet shuttle system is suitable for palletized goods, but small high-frequency items require tote shuttle system or Mini-FlyBox for goods-to-person picking.
3. Define Capacity and Process Requirements
Storage capacity should not be evaluated separately from throughput.
The supplier needs to understand daily inbound volume, outbound peaks, replenishment frequency, order priorities, operating hours, and acceptable waiting times.
4. Evaluate the Building
Warehouse height, floor load, column positions, fire-protection requirements, available entrances, and equipment maintenance routes all affect the final design.
For existing buildings, the system must also fit within fixed structural limitations.
5. Confirm Software Interfaces
The ASRS should connect with existing business systems such as ERP, MES, and upstream WMS systems.
The interface scope should be confirmed early to avoid disconnected equipment and duplicated data entry after installation.
6. Consider Future Expansion
A shuttle-based system can support phased expansion by adding shuttle robots, storage locations, lifters, or handling interfaces.
However, sufficient rail capacity, transfer points, control architecture, and physical space should be planned during the initial design.
Best Practices for Implementing ASRS Shuttle Systems
Use Different Solutions for Different Materials
One of the main strengths of the FAW Toyota project is the use of several storage technologies within one coordinated warehouse.
Pallet shuttle ASRS handles large cages, Mini-FlyBox handles small parts, narrow-aisle racking supports large standardized items, and mezzanine storage accommodates irregular components.
This improves overall system suitability instead of pursuing automation for its own sake.
Standardize Load Units Before Automation
Pallets, cages, and totes entering an automated warehouse should meet the approved dimensional, structural, and load requirements.
Damaged, unstable, overloaded, or non-compliant load units should be handled before they enter the automated system.
Design the Complete Material Flow
The project should not stop at storage equipment selection.
Inbound inspection, pallet transfer, vertical movement, picking, replenishment, returns, abnormal handling, and outbound delivery must be considered as one continuous process.
Unify Equipment Scheduling
Shuttle robots, lifters, conveyors, AGVs, AMRs, and workstations should operate under coordinated software control.
At FAW Toyota, WMS and WCS manage task distribution, route allocation, equipment status, process feedback, and data exchange across multiple zones.
Include Maintenance and Recovery Processes
A practical ASRS design must provide maintenance access, emergency procedures, manual recovery methods, alarm classification, and spare-parts planning.
System availability depends not only on equipment performance but also on how quickly abnormal conditions can be identified and resolved.
Training Staff for Successful ASRS System Operation
Automation changes warehouse roles rather than eliminating the need for people.
Operators need to understand:
- How to release and confirm system tasks
- How to use WMS and operating interfaces
- How to identify abnormal pallets or totes
- How to respond to equipment alarms
- How to handle picking and replenishment exceptions
- When to stop equipment and request maintenance support
Maintenance personnel require more detailed training on shuttle robots, lifters, electrical systems, communication networks, and controlled recovery procedures.
Managers should also understand system data so that they can evaluate equipment utilization, task efficiency, inventory status, and process bottlenecks.
Training should therefore cover daily operation, safety, maintenance, software, and management analysis rather than only basic equipment control.
Measuring the ROI and Efficiency Gains from ASRS Implementation
A complete ROI analysis should include:
- Increased storage capacity
- Reduced warehouse expansion requirements
- Lower internal handling costs
- Faster order response
- Improved inventory accuracy
- Reduced picking and delivery errors
- Better traceability
- Lower dependence on manual experience
- Future capacity expansion
- System maintenance and lifecycle costs
At FAW Toyota, the overall warehouse upgrade shortened the internal supply-chain process by approximately 80%.
The supply cycle was reduced from eight days to two days, improving spare-parts response speed and coordination between storage and distribution.
These results were produced by the complete solution—including storage systems, mobile robots, picking processes, and software integration—rather than by one robot alone.
For similar projects, ROI should be calculated according to the customer’s actual labour costs, building costs, order volumes, inventory levels, and expected business growth.
Exploring Advanced Human-Machine Interaction Systems for Enhanced User Experience and Efficiency
Modern warehouse automation systems need clear and practical human-machine interfaces.
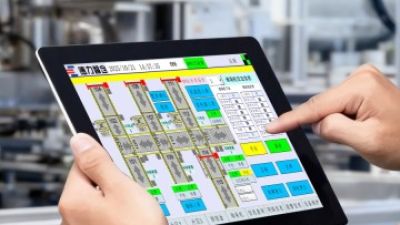
At the FAW Toyota project, a 3D visualization central control system recreates the warehouse layout, equipment status, and material flow through digital-twin technology.
Managers can view the system through a large central display and monitor:
- Inbound and outbound processes
- Equipment operating status
- Current task progress
- Warehouse-zone activity
- Alarm information
- Material movement
- Historical operating data
This improves operational visibility and helps maintenance teams identify abnormal conditions more quickly.
At workstation level, operators interact with the system through fixed terminals, scanners, electronic picking tools, and task interfaces. Required goods are delivered to the operator, while the system guides picking and confirms task completion.
The purpose of human-machine interaction is not to add more screens. It is to provide the correct information to the correct person at the correct stage of the process.
FAQS
Yes. Multiple robots can operate in parallel under WCS control.The system manages task allocation, routes, shared tracks, transfer points, and lift access to prevent conflicts and improve equipment utilization.
Ensure the system can handle high SKU varieties and quick changeovers.
No. Large palletized or caged goods are well suited to pallet shuttle storage, while small parts, irregular items, oils, bumpers, and low-frequency materials may require different storage methods.
A mixed-technology solution is usually more effective for a complex automotive spare-parts warehouse.
Yes. WMS and WCS can exchange data with ERP, MES, sales systems, and upstream warehouse platforms through project-specific interfaces.The interface requirements, task ownership, data fields, and exception-handling logic should be confirmed during the planning stage.
The main information includes warehouse drawings, building height, pallet or cage specifications, load weight, SKU quantity, inventory capacity, inbound and outbound volume, operating hours, software interfaces, and future expansion plans.
Conclusion
The FAW Toyota project demonstrates how an ASRS shuttle system can support a complex automotive spare-parts warehouse with nearly 45,000 SKUs.
DELIECN used pallet four-way shuttle robots for large caged parts, Mini-FlyBox for small items, multiple racking systems for special materials, and AGVs and TOTE AMRs for cross-zone transportation.
Through WMS/WCS integration and unified equipment scheduling, the project connects inbound handling, storage, replenishment, picking, transportation, outbound operations, and traceability within one digital workflow.
The value of the system lies not only in higher storage density. It also provides a more responsive, accurate, scalable, and visible spare-parts logistics process.
Planning an automotive spare-parts warehouse or ASRS shuttle project? Share your warehouse layout, load-unit specifications, SKU structure, required capacity, and operating process with DELIECN for a customized solution assessment.

 Industries
 Services
 About Us
 AS/RS Handling Robot
 Vertical Storage Module
 Conveying Equipment
 Smart Warehousing System
 Warehouse Racking